Featured topics
Topic AI Development
40 articles


 3D
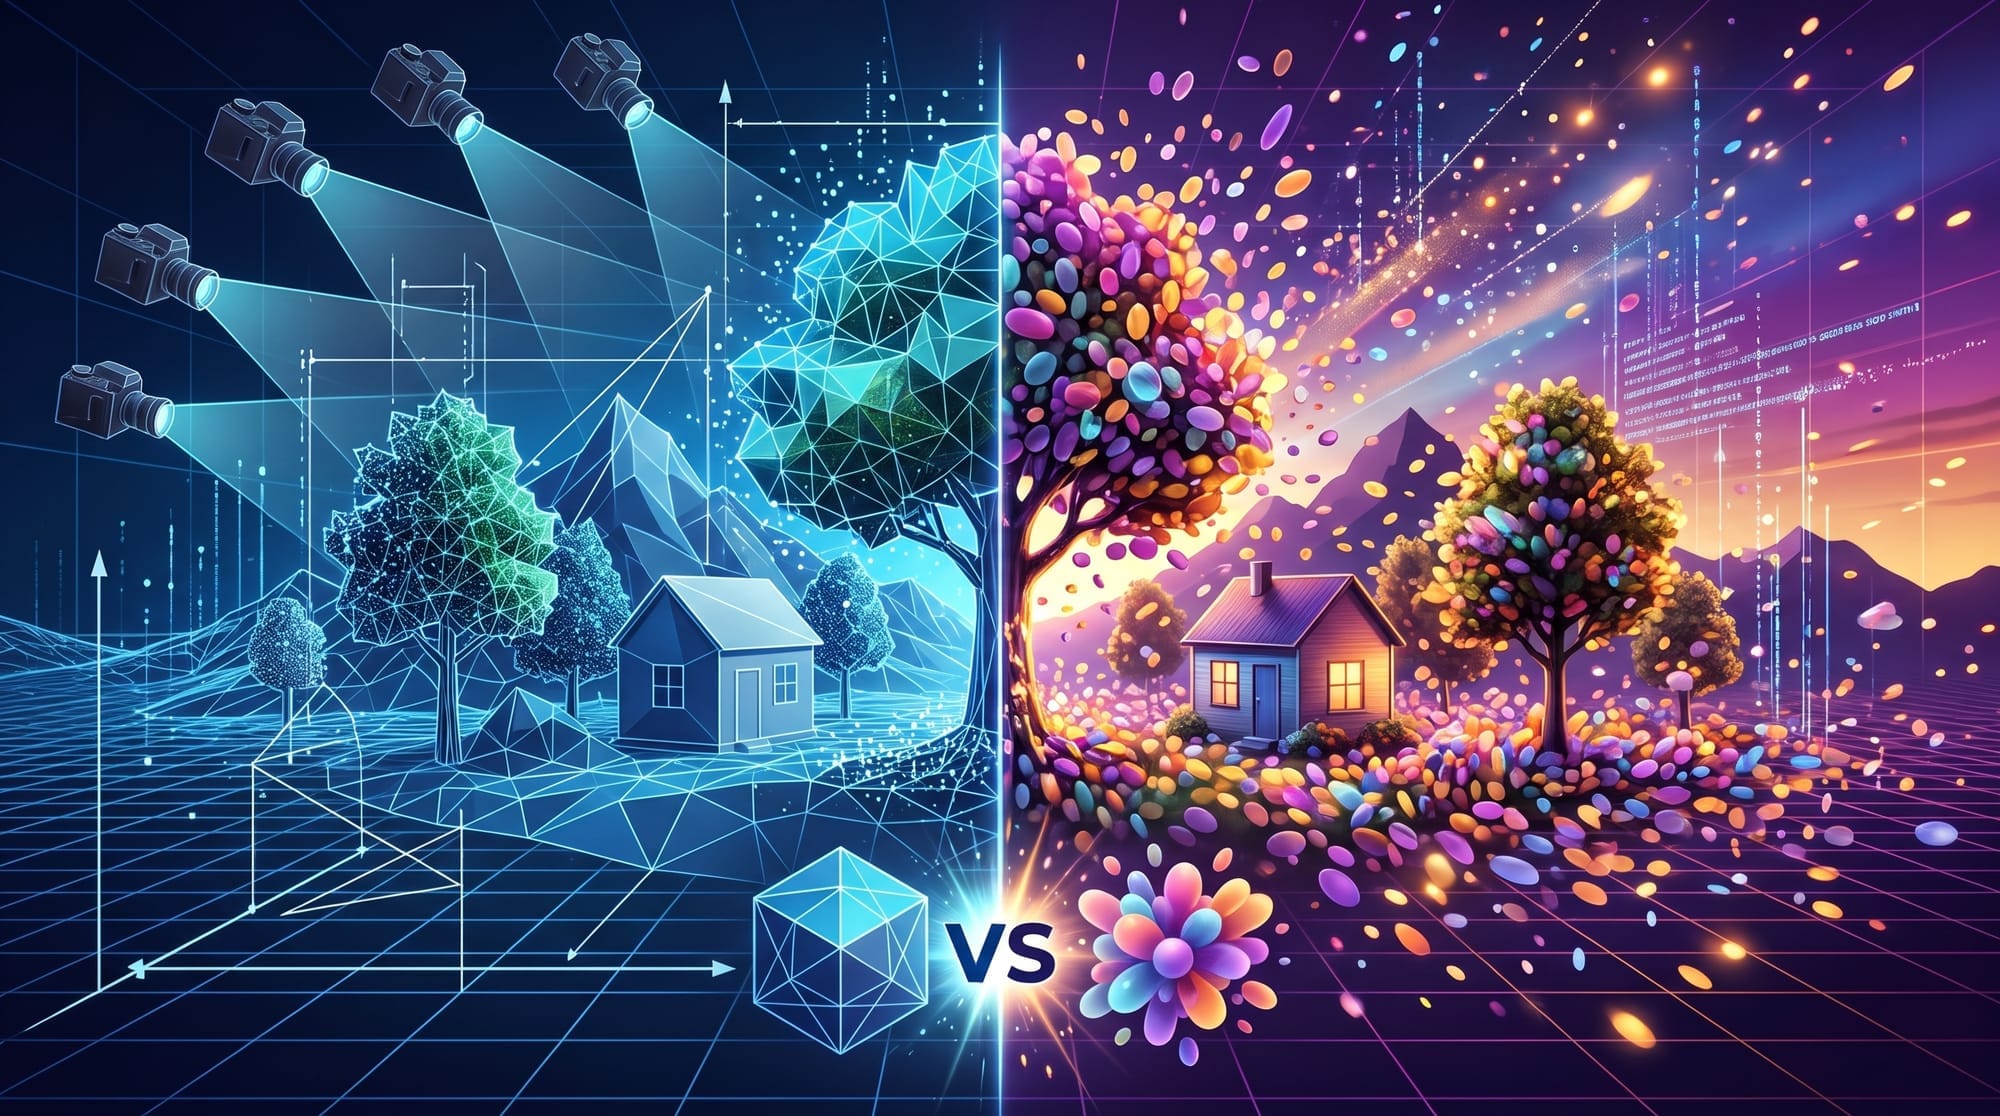
Understanding 3DGS, Part 2: How Is 3DGS Different from Photogrammetry?
3DGS and photogrammetry both reconstruct 3D scenes from multiple photos and share key SfM steps. This article explains where they diverge: photogrammetry continues to MVS, dense point clouds, meshes, and textures, while 3DGS optimizes Gaussians to reproduce photorealistic views.
 3D
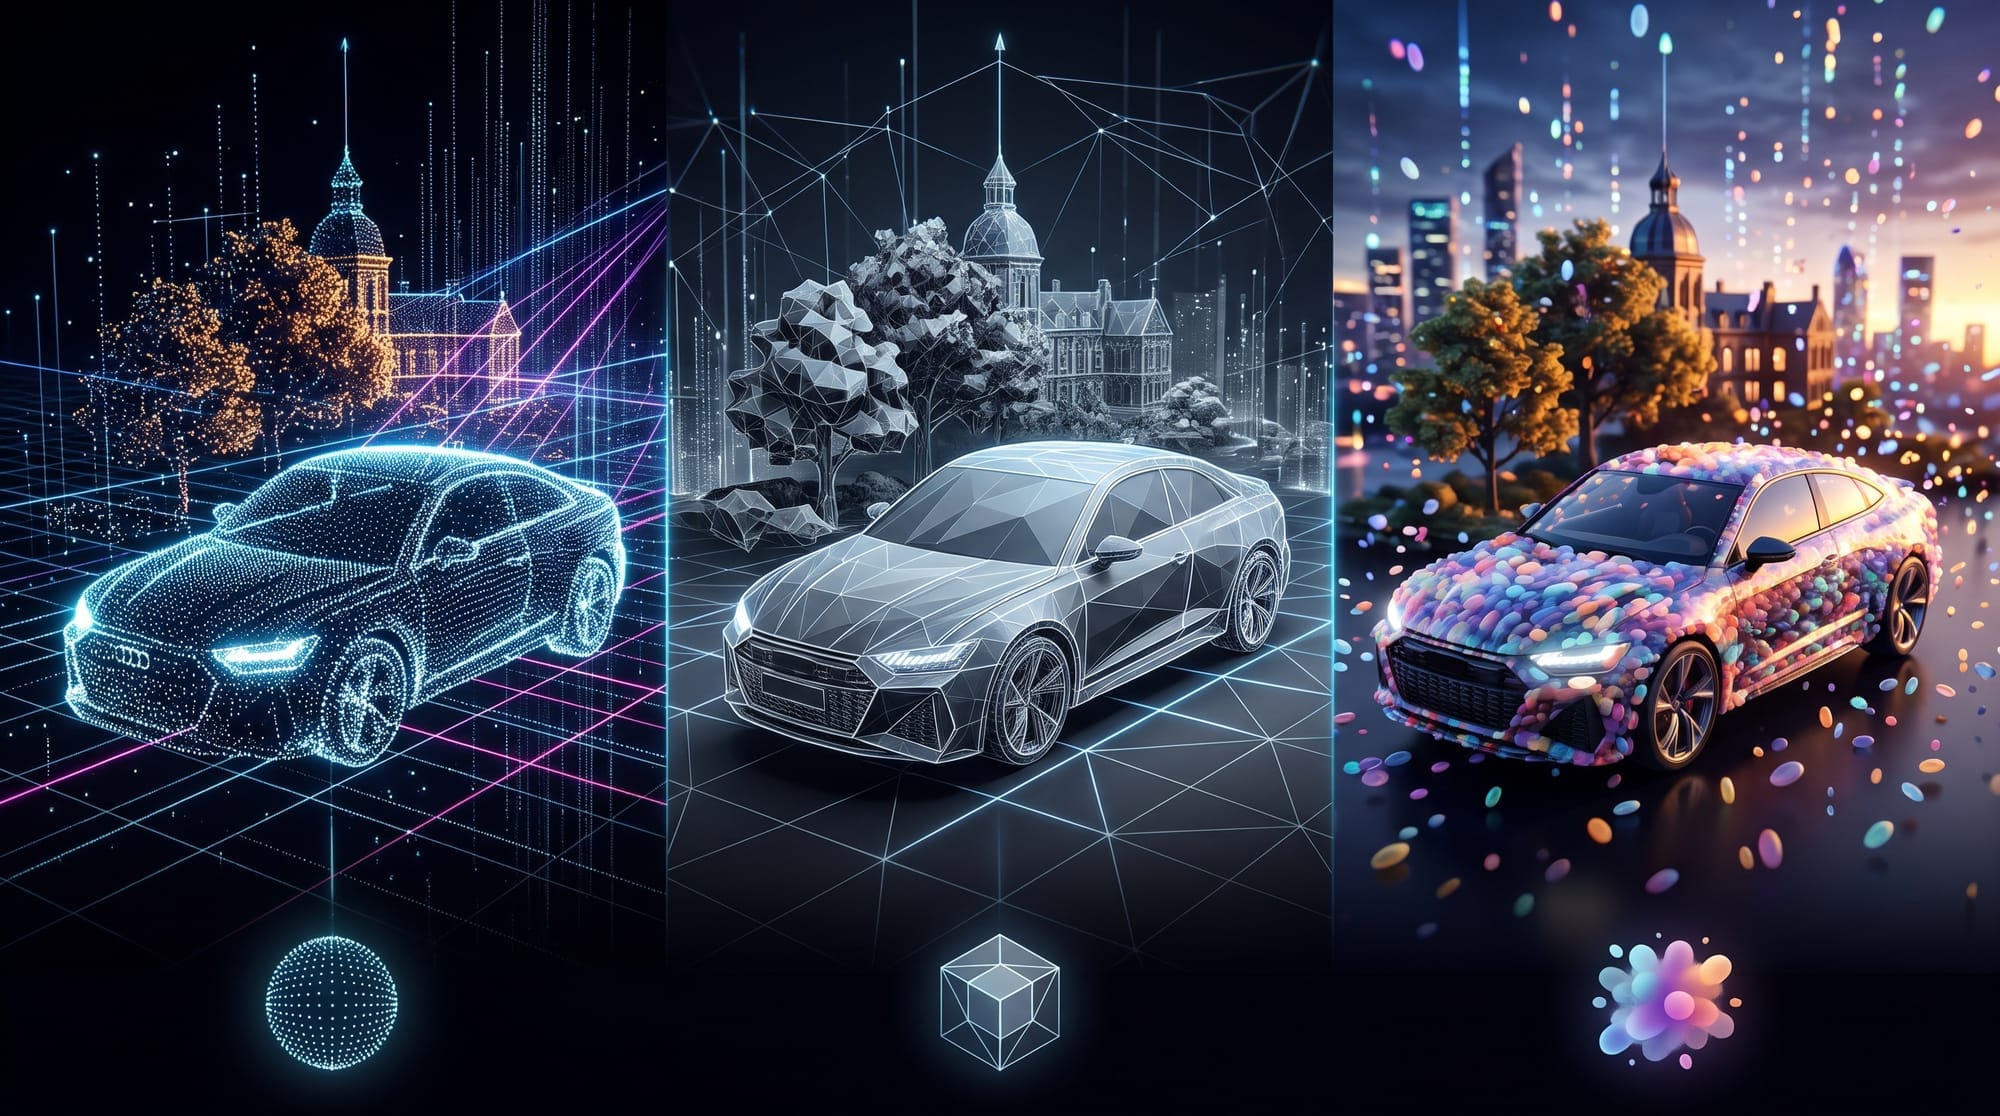
Understanding 3DGS, Part 1: How Is 3DGS Different from Traditional 3D Modeling?
3DGS reconstructs real-world scenes with large numbers of Gaussians, while traditional 3D modeling uses meshes, textures, and materials. This article explains how the two approaches differ, where each works best, their limitations, and how 3DGS may change the way real spaces are digitized.
 3D
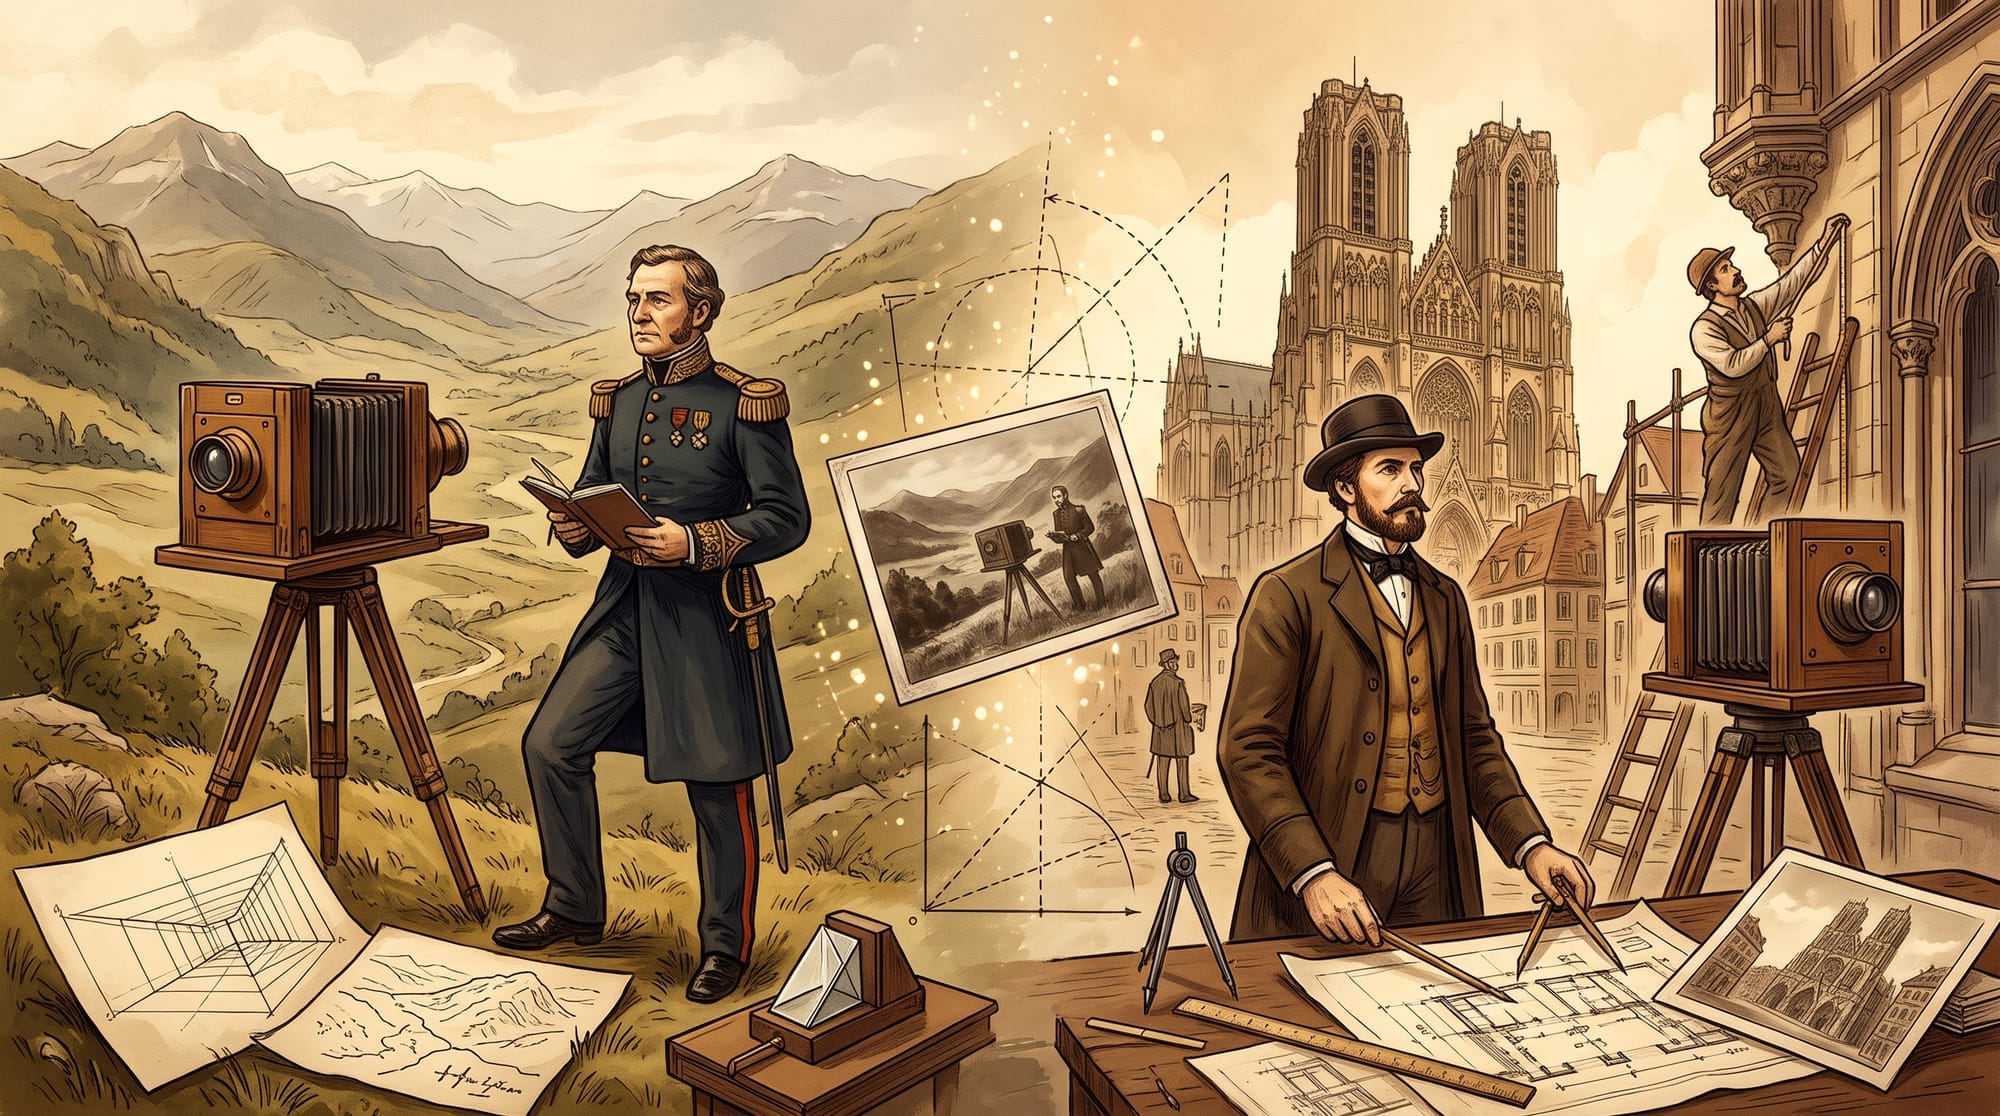
Understanding 3DGS, Part 0: How Do Photos Become 3D? — 170 Years of Trial and Error
How did photos become 3D? This article traces the evolution from 19th-century photogrammetry and stereo vision to SfM, MVS, NeRF, 3D Gaussian Splatting, and 2DGS, explaining how photography evolved from a recording medium into a tool for reconstructing and revisiting real-world spaces.
 AI Development
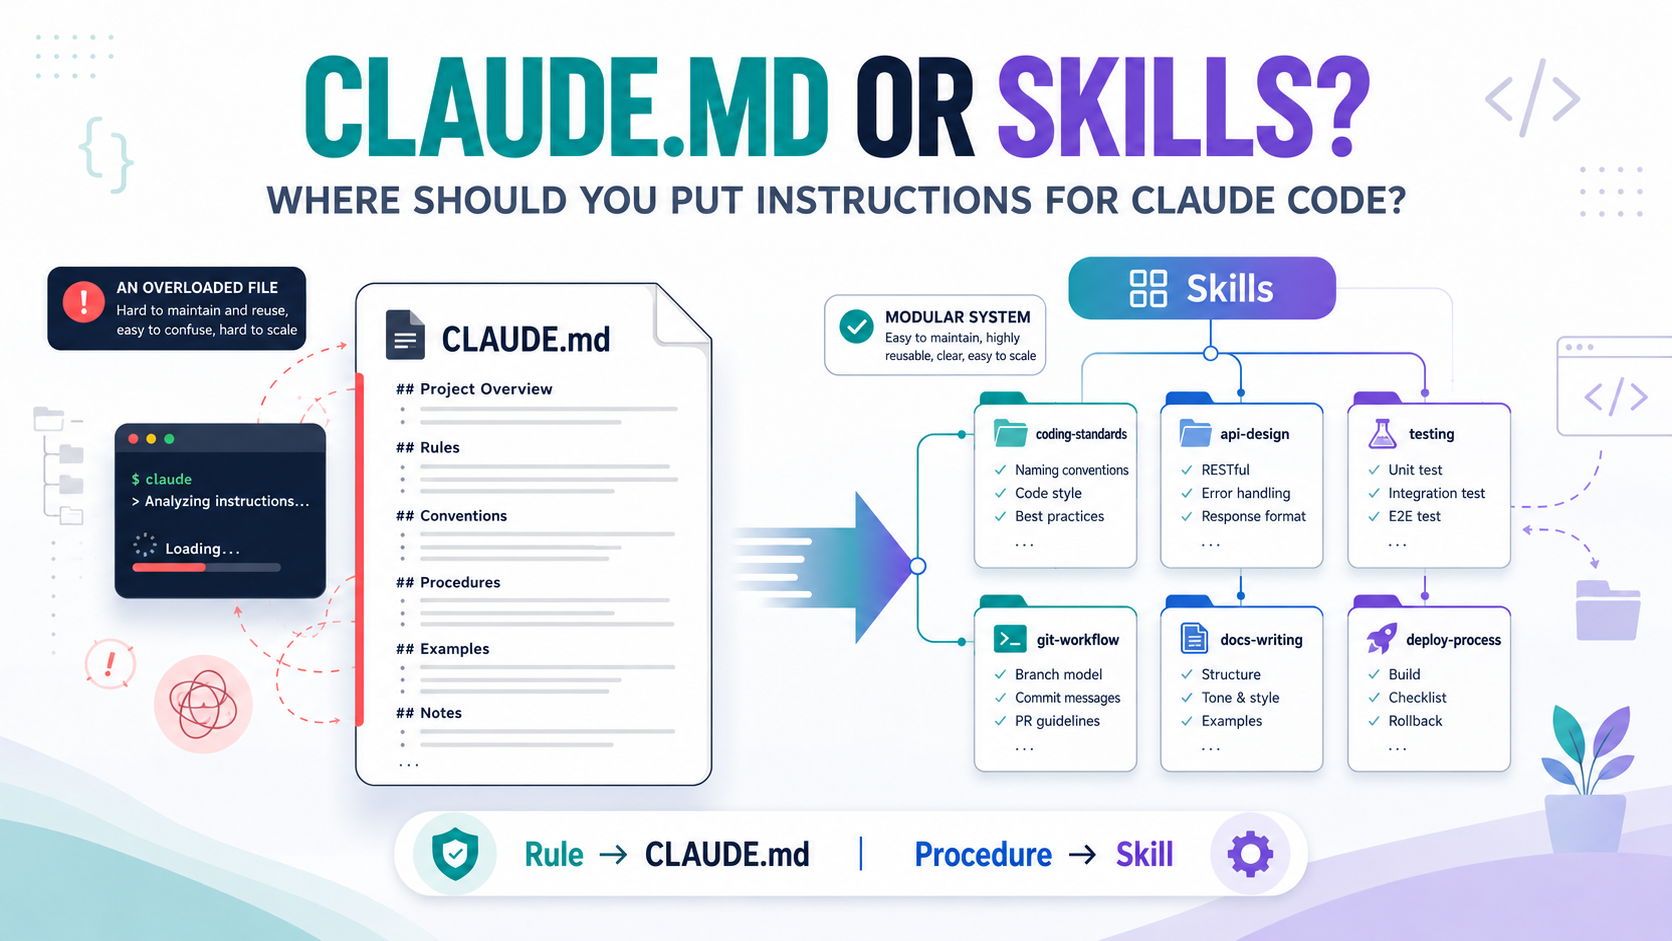
CLAUDE.md vs Skills: Where Should Claude Code Instructions Go?
CLAUDE.md should not store every project instruction. This guide explains when to use CLAUDE.md, Skills, .claude/rules/, and Hooks in Claude Code, with examples and a decision tree for organizing project context, task workflows, scoped rules, and deterministic automation.
 AI Development
Cyc — 40 Years of Trying to Write Common Sense by Hand
Cyc is an AI project launched in 1984 to encode human common sense by hand. This article traces Douglas Lenat’s path from AM and Eurisko to CycL, microtheories, OpenCyc, the contrast with LLMs, and the renewed interest in neuro-symbolic AI.
 AI Development
Isaac Sim Is Not Just a Heavyweight Unity — 4 Decisive Reasons to Move Beyond ML-Agents
Isaac Sim and Unity ML-Agents both support reinforcement learning, but differ greatly in architecture and robotics focus. This article compares GPU parallelism, contact physics, domain randomization, sensor simulation, and ROS 2/URDF/USD integration, while showing where Unity still excels.
 AI Development
What Is Reinforcement Learning? What Was Happening Behind That “Extra-Dimensional Fight”?
Using our NVIDIA Isaac Sim robot sumo experiment, this article explains reinforcement learning through state, action, environment, reward, and trial and error. It also shows how RL differs from supervised learning and why the robots discovered lariats, folded arms, and aerial attacks.
 AI Development
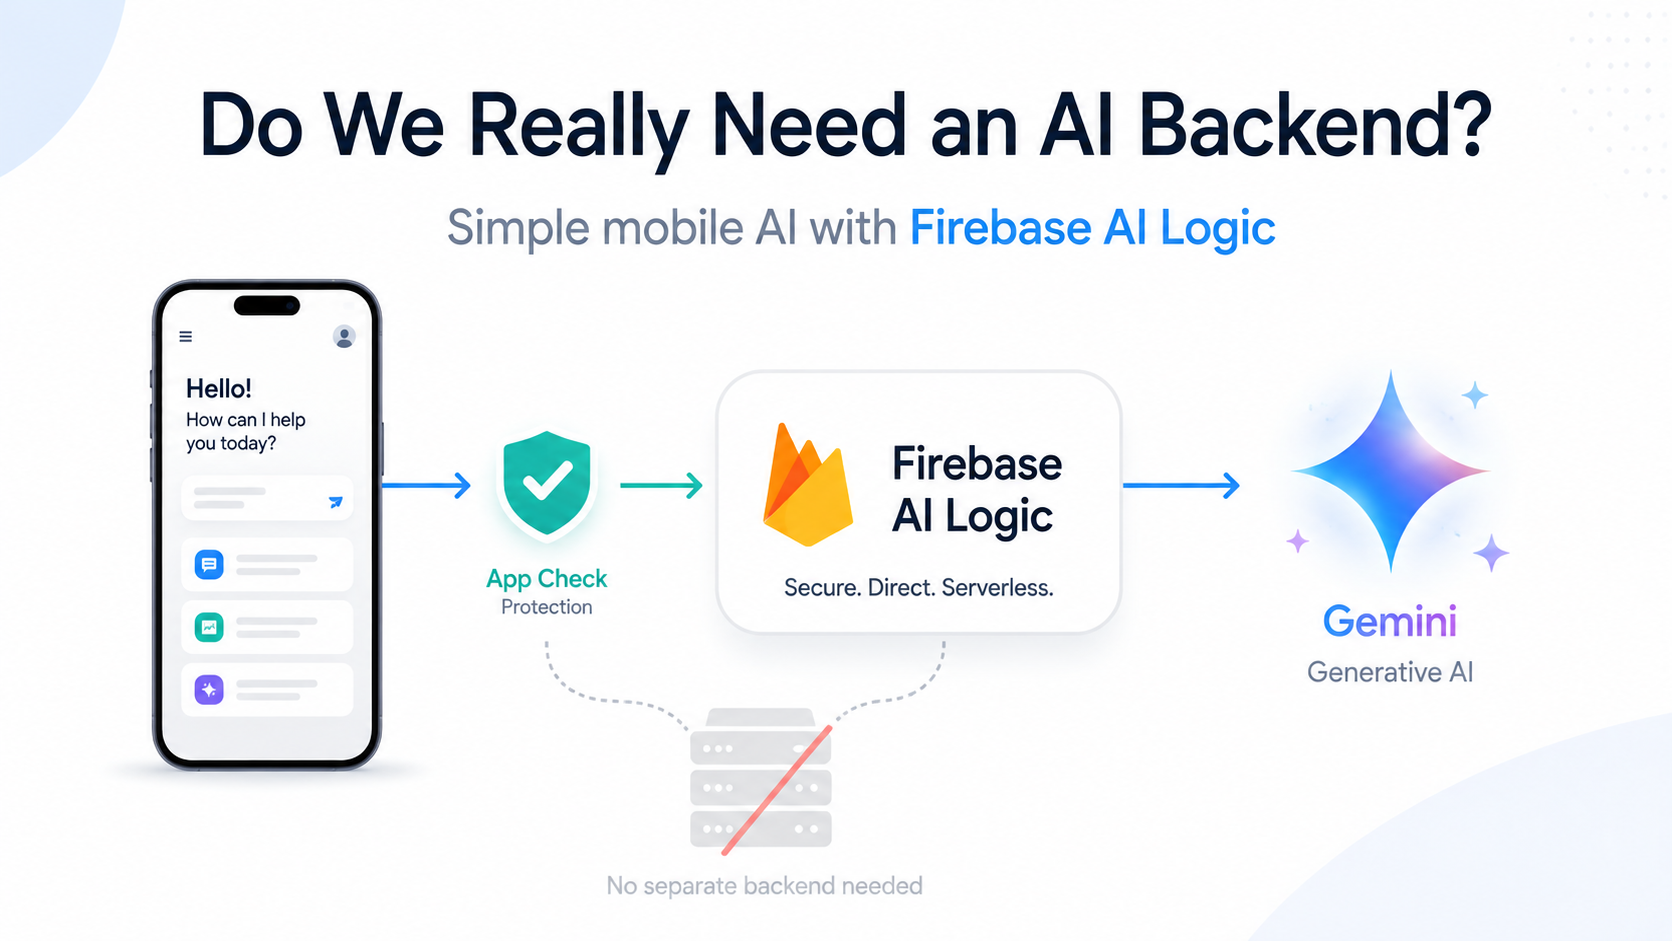
Ship Production AI Features Faster with Firebase AI Logic
A practical guide to shipping Gemini-powered AI features with Firebase AI Logic. Learn how App Check, rate limits, Server Prompt Templates, and Template-only Mode can reduce backend complexity—and when RAG, private APIs, trusted operations, or complex workflows still require a backend.
 AI Development
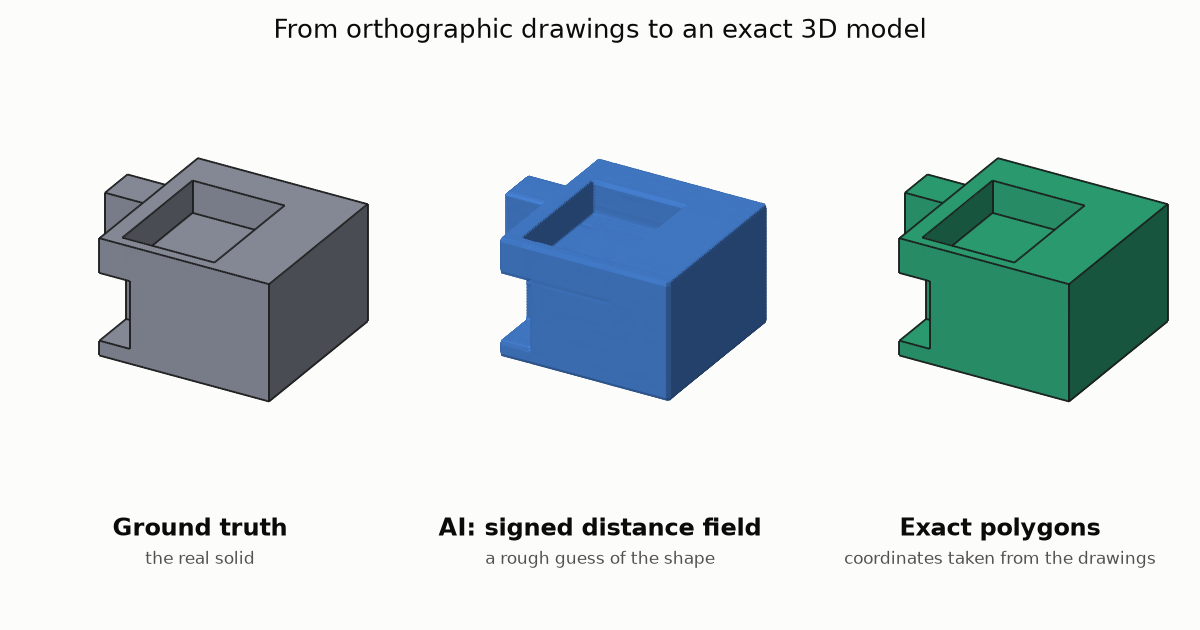
AI That Reconstructs 3D Shapes from Orthographic Drawings — Using SDF to Capture the Rough Shape
We prototype an AI system that reconstructs 3D models from top, front and side views. Using SDF as a shape draft and exact coordinates from drawings, it achieved 97.1% mean IoU on 500 unseen tests, with 72.5% exact matches on box-based shapes. We also cover validation, limits and next steps.
 AI Development
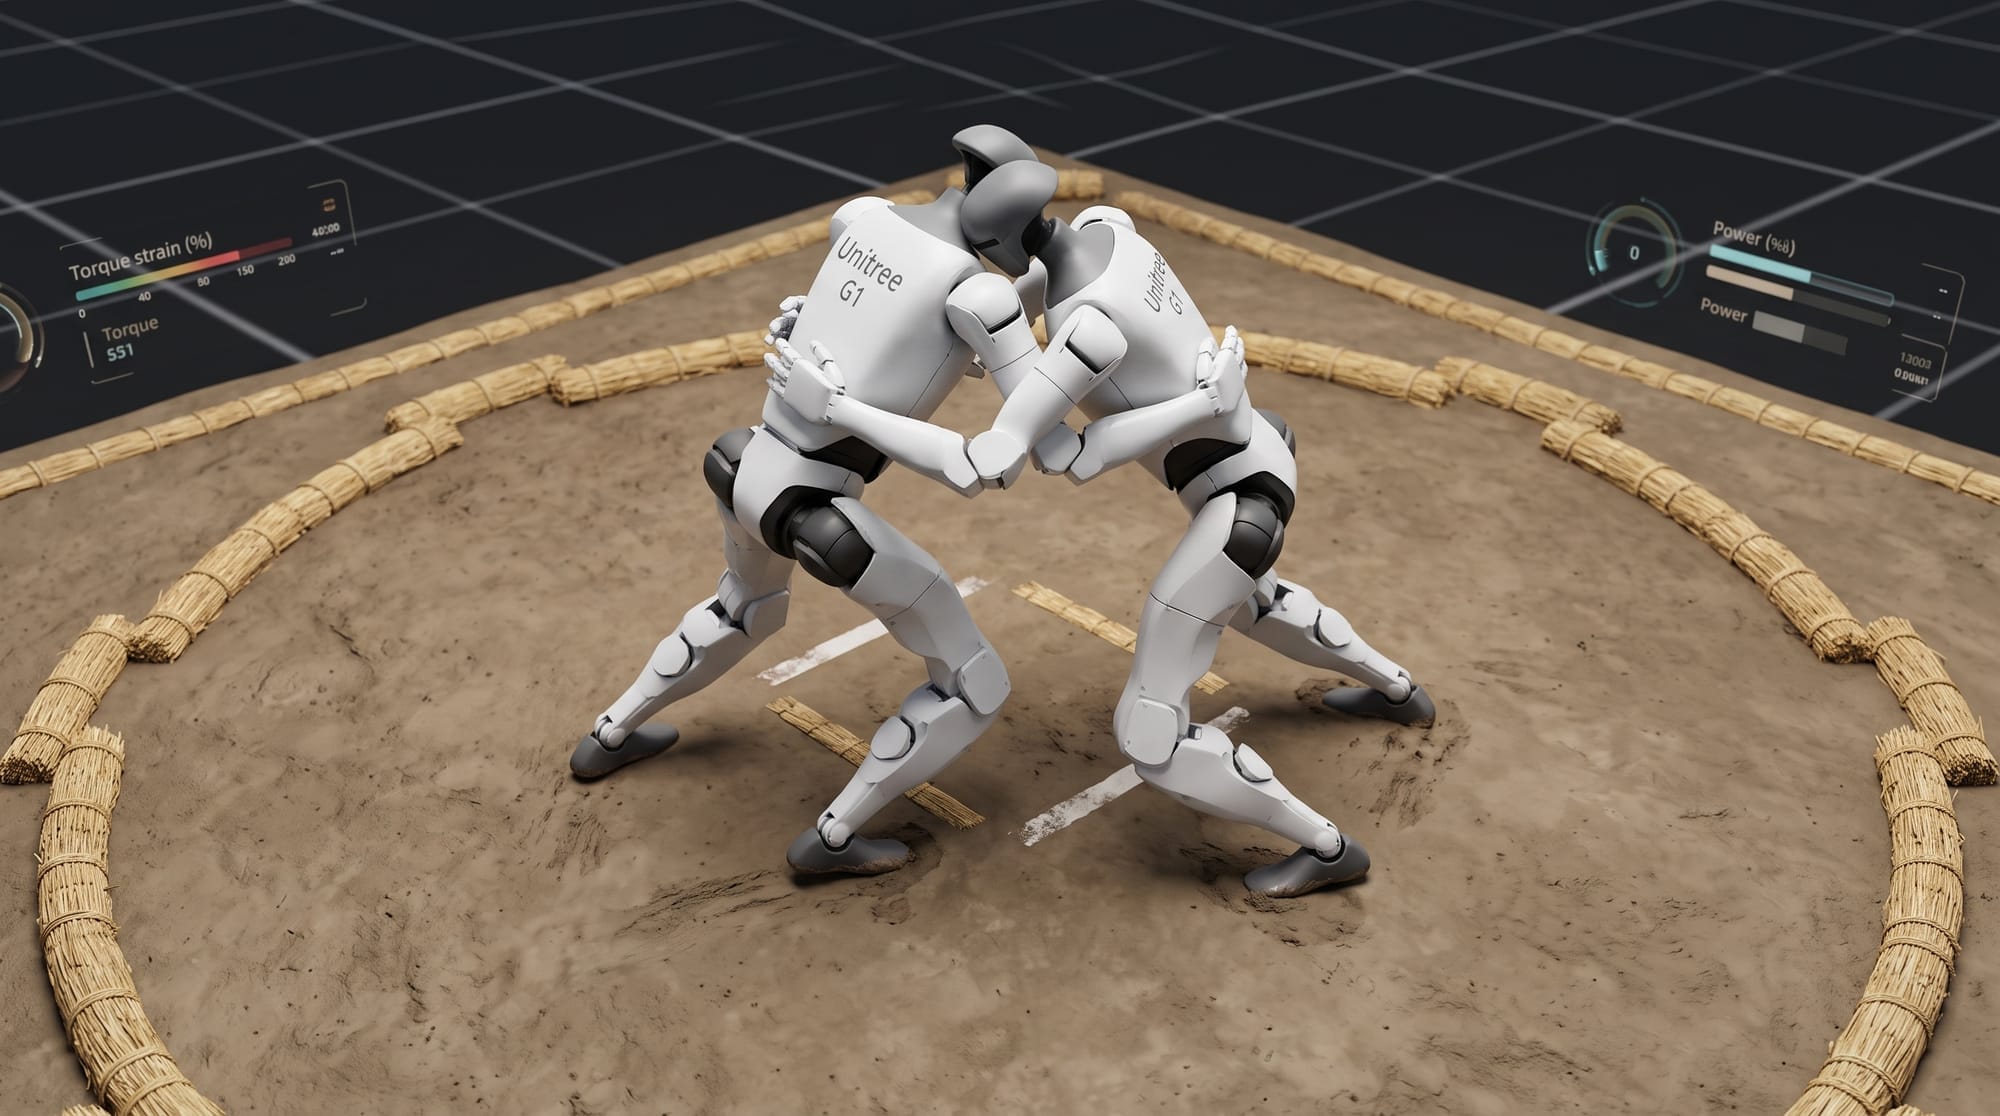
We Taught Robots "Sumo"—and They Mastered Lariats, Cossack Dancing, and Aerial Combat
We trained two robots to fight sumo in NVIDIA Isaac Sim and tracked their evolution from Epoch 1 to 100. The experiment explores reinforcement learning, Sim-to-Real, domain randomization, and the unexpected strategies the AI discovered—from lariats and kicks to low stances and aerial combat.
 AI Development
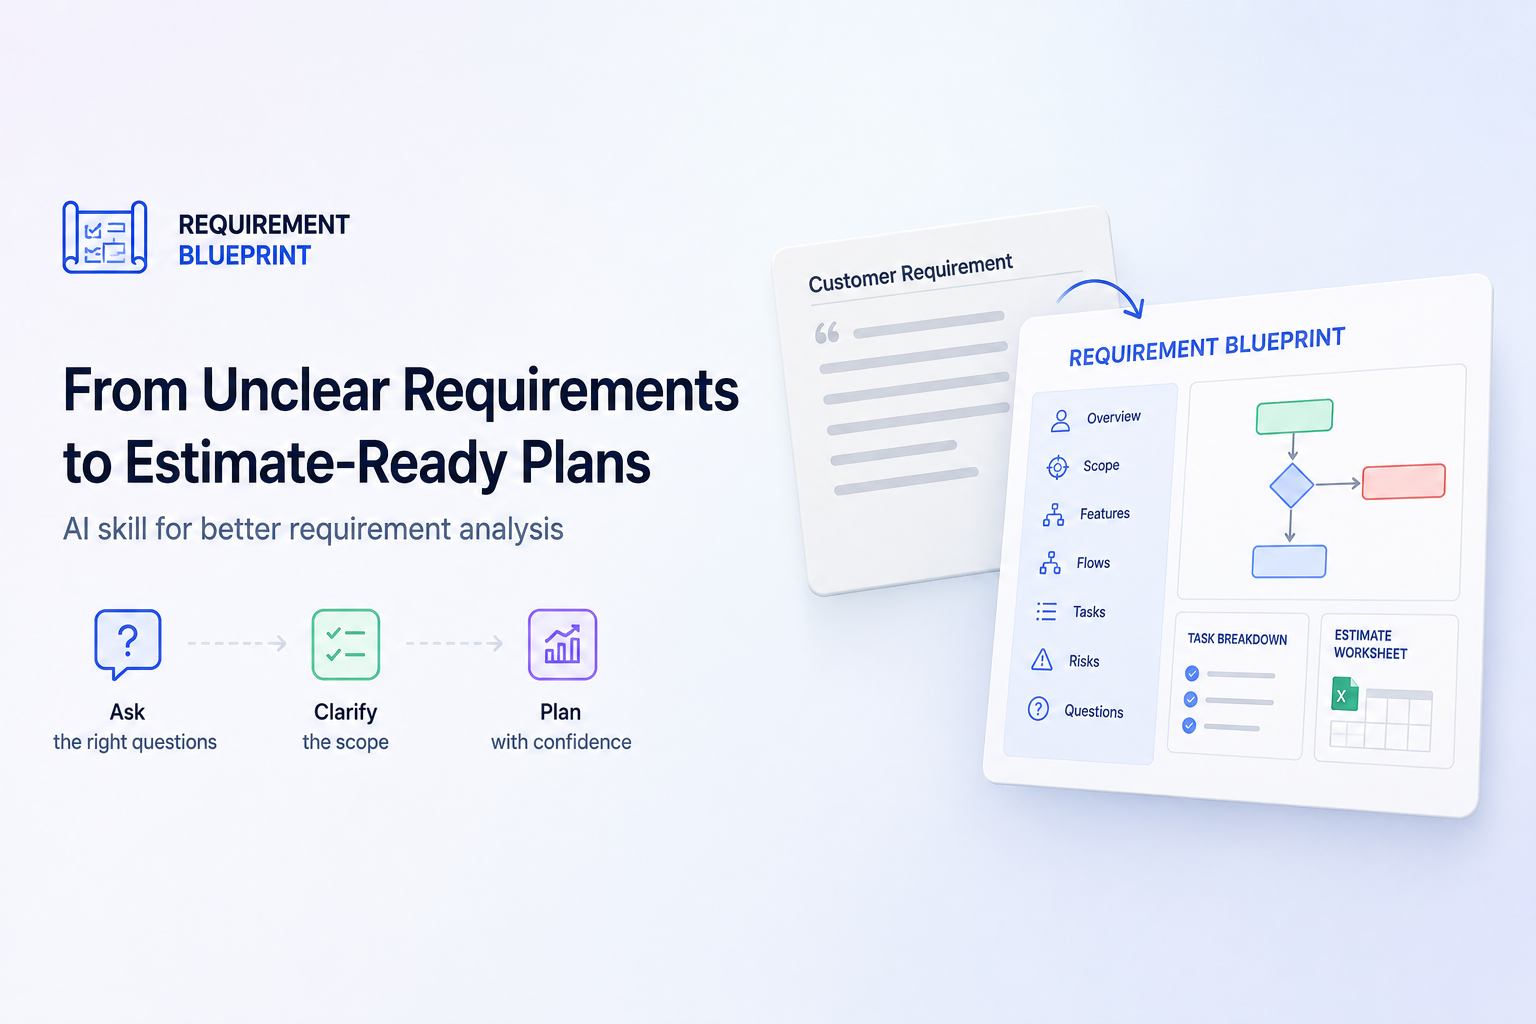
Developed an Agent Skill for estimating ambiguous requirements
Requirement Blueprint is an Agent Skill that helps AI analyze ambiguous customer requirements before estimation. It structures scope, features, flows, tasks, open questions, and risks while separating confirmed facts from assumptions. Benchmarks showed a 26.9% higher average score than baseline.
 AI Development
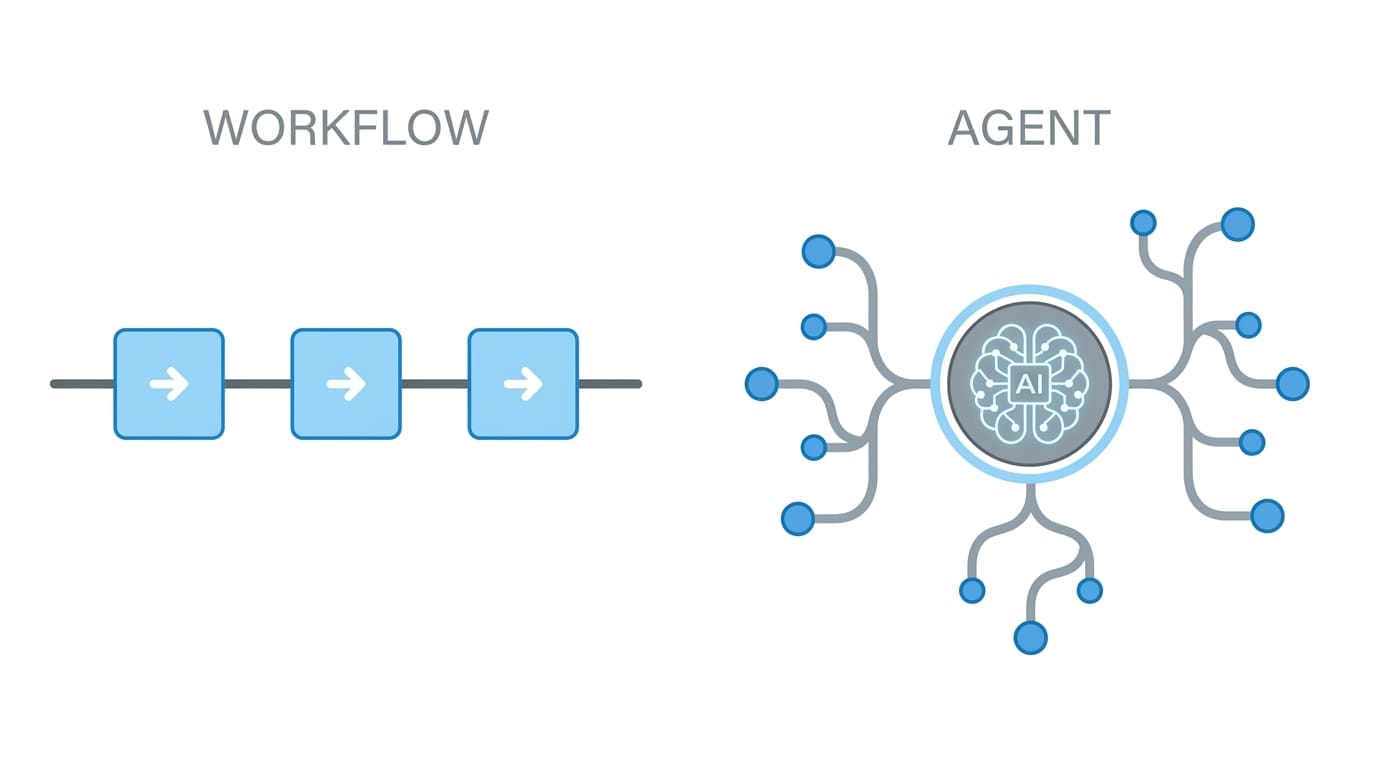
How to Think About LLM Workflow Design | More Tasks Than You Think Do Not Need AI to Decide What to Do
A practical guide to designing multi-step AI systems. Learn the difference between fixed LLM workflows and AI agents, how step boundaries enable retries and testing, how to handle waiting and idempotency, and why a hybrid workflow-plus-agent architecture often works best.
